The SC series at a glance
HIKROBOT sells its compact camera-based devices in two groups, and uses the names consistently: the SC1000, SC2000 and SC3000 series are vision sensors, and the SC5000X and SC6000 series are smart cameras running the VisionMaster platform with deep-learning modules. Resolution ranges and tool groups below are as HIKROBOT states them (HIKROBOT catalogue 2025 Q4); the “typical fit” column is our view.
| Series | HIKROBOT category | Resolution (vendor) | Tools (vendor) | Typical fit |
|---|---|---|---|---|
| SC1000 | Vision sensor | 0.3–0.8 MP | Existence, count, measurement, recognition tools; smallest body | Simple error-proofing: part present, right way round, a count |
| HIKROBOT SC2000 (SC2000E) | Vision sensor | 0.4–1.6 MP | Adds position, defect, logic, pattern tools and OCR | Presence, orientation and simple print or character checks |
| HIKROBOT SC3000 (SC3000X) | Vision sensor | 1.6–5 MP | Adds code recognition, match location, DL classification and detection, image storage | Checks that need a code read or a trained classifier in one compact unit |
| SC5000X | Smart camera | 2–12 MP | VisionMaster platform including deep-learning modules | One or two checks with the full tool set, including segmentation |
| HIKROBOT SC6000 | Smart camera | 1.6–25 MP | VisionMaster platform including deep-learning modules | Higher resolution or heavier solutions in one camera |
HIKROBOT’s five selection steps, with our notes
HIKROBOT’s own selection guide for smart cameras runs in five steps (HIKROBOT catalogue 2025 Q4). We follow the same order and add what we check on real projects.
| Step | HIKROBOT guide | Our note |
|---|---|---|
| 1. Camera type | Integrated lens and light (easy set-up) or C-mount (lens chosen from field of view and working distance). | Take the C-mount version when the working distance or field of view is not standard, or when the lighting must be separate from the camera. |
| 2. Focus adjustment | Choose by how focus is set on the model. | Lock focus after set-up; a change of product height needs a recipe or mechanical adjustment. |
| 3. Algorithm capability | Pick the series whose tool set covers the checks. | Check OCR, code reading and deep-learning needs first; they rule out the smaller sensors. |
| 4. Algorithm performance | Compare processing time with the production cycle time. | Test with the real solution on real images; add margin for the reject timing. |
| 5. Hardware limits | Module and solution limits, image saving in the camera or via FTP. | Many products or large solutions point to SC5000X/SC6000 or a controller. |
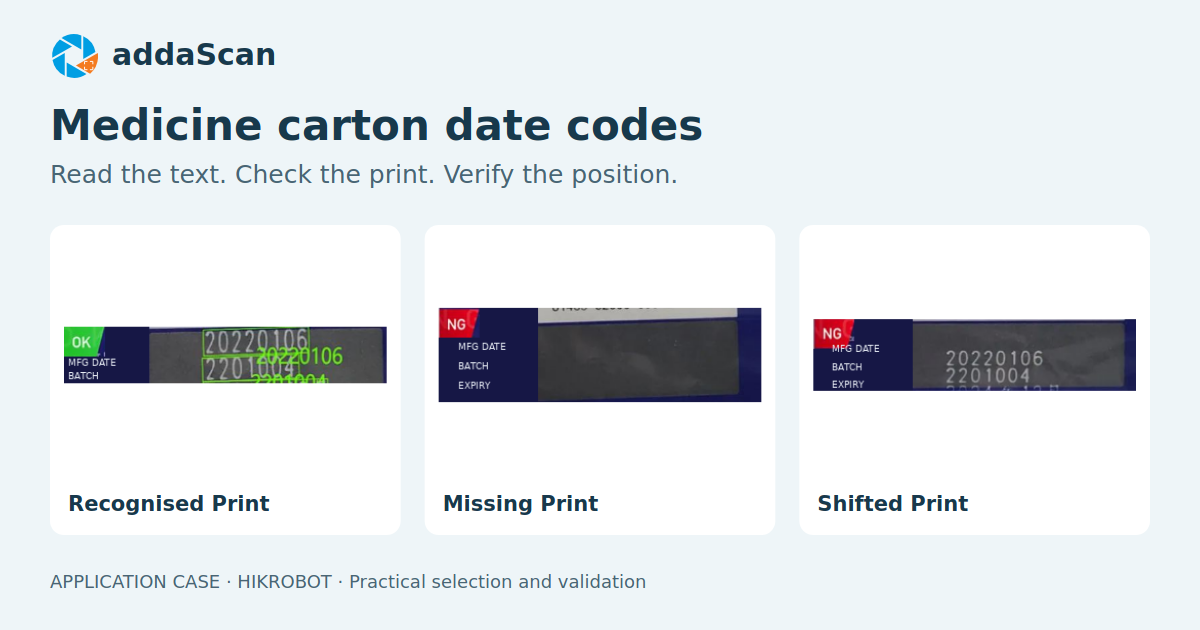
Date codes: readable does not always mean acceptable
A published SC5000 medicine-carton application combines character recognition with print and position checks. Use its fault examples to define the task before selecting a current model.
Read the application guide →Define the required views, inspection tasks, worst-case timing and PLC outputs before choosing a device. Use the station scope guide to separate the camera from optics, handling, reject control and acceptance; the HIKROBOT and other vision solutions comparison helps compare equivalent responsibilities and support needs.
Models and what HIKROBOT lists for each
The table lists representative models from HIKROBOT’s product pages and its 2025 Q4 catalogue specification tables (HIKROBOT catalogue 2025 Q4). The SC5000X and SC6000 rows below identify monochrome M variants from that catalogue. Colour C and V2 variants may have different sensor dimensions; do not transfer the M row to them. Listed integrated focal lengths and C-mount options are ordering alternatives, not interchangeable lenses supplied with every camera. Vision-sensor details come from the product pages of the SC1000, SC2000E and SC3000X (HIKROBOT SC1000)(HIKROBOT SC2000E)(HIKROBOT SC3000X).
| Model (vendor) | Resolution | Max. frame rate | Sensor | Lens | Other vendor-stated details |
|---|---|---|---|---|---|
| SC1000 (0.8 MP mono) | 1024 × 768 | 15 fps | – | Integrated | Existence, count, measurement and category tools; built-in white LED; IP54 |
| SC2000E (colour) | 704 × 540 | 60 fps | – | Integrated | Colour measurement, size and count, colour recognition, OCR; IP65; PROFINET, EtherNet/IP, Modbus |
| SC3000X | 1216 × 1024 | 60 fps | – | Integrated | Learning-based count, OCR, code recognition, deep-learning detection; IP67 with lens cap; 3 inputs, 3 outputs |
| MV-SC5020XM | 1600 × 1216 | 100 fps | 1/2.53", 3.45 µm | 6, 12 or 16 mm, or C-mount | VM platform including deep-learning modules |
| MV-SC5050XM | 2432 × 2048 | 60 fps | 1/1.45", 3.45 µm | 8, 12 or 16 mm, or C-mount | VM platform including deep-learning modules |
| MV-SC5120XM | 4096 × 2944 | 30 fps | 1/1.1", 3.45 µm | C-mount | VM platform including deep-learning modules |
| MV-SC6016M | 1408 × 1024 | 120 fps | 1/2.53", 3.45 µm | 6, 12 or 16 mm, or C-mount | VM platform including deep-learning modules |
| MV-SC6050M | 2432 × 2048 | 80 fps | 1/1.45", 3.45 µm | 8, 12 or 16 mm, or C-mount | VM platform including deep-learning modules |
| MV-SC6120M | 4096 × 2944 | 40 fps | 1/1.1", 3.45 µm | C-mount | VM platform including deep-learning modules |
| MV-SC6250M | 5120 × 5120 | 20 fps | 1/1.1", 2.5 µm | C-mount | VM platform including deep-learning modules |
Worked example: field of view, pixel size and cycle time
Field of view follows from the sensor width, the working distance and the lens. The sensor width is the pixel count times the pixel size; for the 2,432-pixel models it is about 8.4 mm. With the thin-lens approximation, field of view ≈ sensor width × working distance ÷ focal length. This is a hypothetical first-pass calculation at a nominal 200 mm object distance, assuming a thin lens and small magnification. Working distance from the lens housing is not the principal-plane distance used by the optical model. The 8, 12 and 16 mm columns are mathematical lens choices, not a promise that every model offers each integrated lens. Check the exact lens variant, distortion, focus range and depth of field on samples; these figures are not bench measurements.
| Model width in pixels | Sensor width (pixels × 3.45 µm) | FOV at 200 mm with 8 mm lens | with 12 mm | with 16 mm | Pixel size if the FOV is 80 mm |
|---|---|---|---|---|---|
| 1,408 (SC6016) | 4.9 mm | about 121 mm | about 81 mm | about 61 mm | 0.057 mm |
| 2,432 (SC5050X, SC6050) | 8.4 mm | about 210 mm | about 140 mm | about 105 mm | 0.033 mm |
| 4,096 (SC5120X, SC6120) | 14.1 mm | C-mount lens chosen to suit | 0.020 mm |
Cycle time. In a hypothetical line running 300 packs a minute, the product interval is 200 ms. The SC6050 catalogue maximum of 80 fps corresponds to a nominal 12.5 ms frame period. That is not the exposure, trigger-to-result latency or complete inspection time. Budget exposure, readout, transfer, processing, PLC communication and reject actuation separately; test their combined worst observed delay with margin under production load. The solution’s processing time on real images decides whether the model is fast enough; HIKROBOT’s selection step 4 says the same (HIKROBOT catalogue 2025 Q4).
Configuring a smart camera station
- Mount and light: fixed position, working distance from the specification, shroud against daylight; external light where the built-in one is not enough.
- Connect: set the IP address and communication in SCMVS (vision sensors) or SC_VisionMaster (SC5000X, SC6000).
- Image: focus, exposure and light on real products; HIKROBOT offers one-key adjustment of brightness, focus and white balance on its smart cameras (HIKROBOT catalogue 2025 Q4), which we then fine-tune and lock.
- Solution: locate the product, add the inspection tools, set limits on the sample set, combine in logic.
- I/O: trigger input, pass/fail and result-valid outputs or a network protocol to the PLC; recipe (solution) switching from the PLC for each product.
- Records: save failed images in the camera or to a server by FTP, and back up the solution.
The full procedure is in the commissioning procedure; which tools to use is in VisionMaster algorithm tools.
When a vision controller and separate cameras fit better
A smart camera is one view. For all-round label checks on round bottles, empty bottle base, sidewall and finish views, or several deep-learning checks, a vision controller running VisionMaster with separate GigE cameras is the usual choice. HIKROBOT positions its VC2000 controller for simple multi-camera applications, the VC3000 for demanding positioning, inspection, measurement and recognition tasks, and the VC5000 as an AI edge computing platform with modular expansion (HIKROBOT catalogue 2025 Q4). See typical HIKROBOT configurations.
Troubleshooting a smart camera station
Most problems after go-live are lighting, solution switching and I/O, not the camera itself. Light geometry is explained in HIKROBOT’s light-source glossary (HIKROBOT light catalogue); I/O wiring to a PLC is documented for HIKROBOT’s VC3000 controllers (HIKROBOT VC3000 datasheet), but controller pinouts and electrical ratings must not be transferred to a smart camera without its own wiring diagram. Configuration clients (SCMVS for vision sensors, SC_VisionMaster for smart cameras) come from HIKROBOT’s download centre (HIKROBOT download centre).
| Symptom | Likely cause | What to check or change |
|---|---|---|
| Results vary with the time of day | Daylight or room light reaching the part | Shroud the station; external light with the built-in light off; check exposure |
| Glare on shiny packs hides print | Light reflecting straight into the lens | Change the light angle; dome or polarised light; HIKROBOT’s light glossary explains the geometry |
| Good parts fail after a product change | Wrong solution active, or focus set for another height | Solution switching from the PLC with a handshake; lock focus per product |
| Result arrives too late for the reject | Processing time longer than the time to the reject | Time the solution on real images; simplify tools, use a faster model or move the reject |
| Outputs do nothing in the PLC | NPN/PNP mismatch or wrong signal mapping | Use the electrical diagram for the exact camera and PLC input module; verify sourcing/sinking, voltage, common and output load before wiring |
| No images of failures to review | Image saving not set, or storage full | Save failed images in the camera (from SC3000X) or by FTP to a server; set retention |